 ZEROIQ'S
01 / PROTOTYPE
Video Prototypes
Demonstrating both systems in action, evaluating edge cases and core architecture validation.
PS 26037
Collision Intelligence (C-I)
Collision Intelligence Prototype - System Overview
Demonstrating the Camera + LiDAR + Radar sensor fusion and real-time obstacle detection.
Simulated Navigation on Unstructured Indian Roads
Vehicle simulation demonstrating real-time obstacle avoidance and path planning using Hybrid A* and NLMPC in chaotic traffic scenarios.
PS 26025
AI-Enabled Wireless Surface Mesh Network
Mine Subsidence Intelligence - Hardware Node
Demonstrating the ESP32 sensor node collecting tilt, vibration, and strain data.
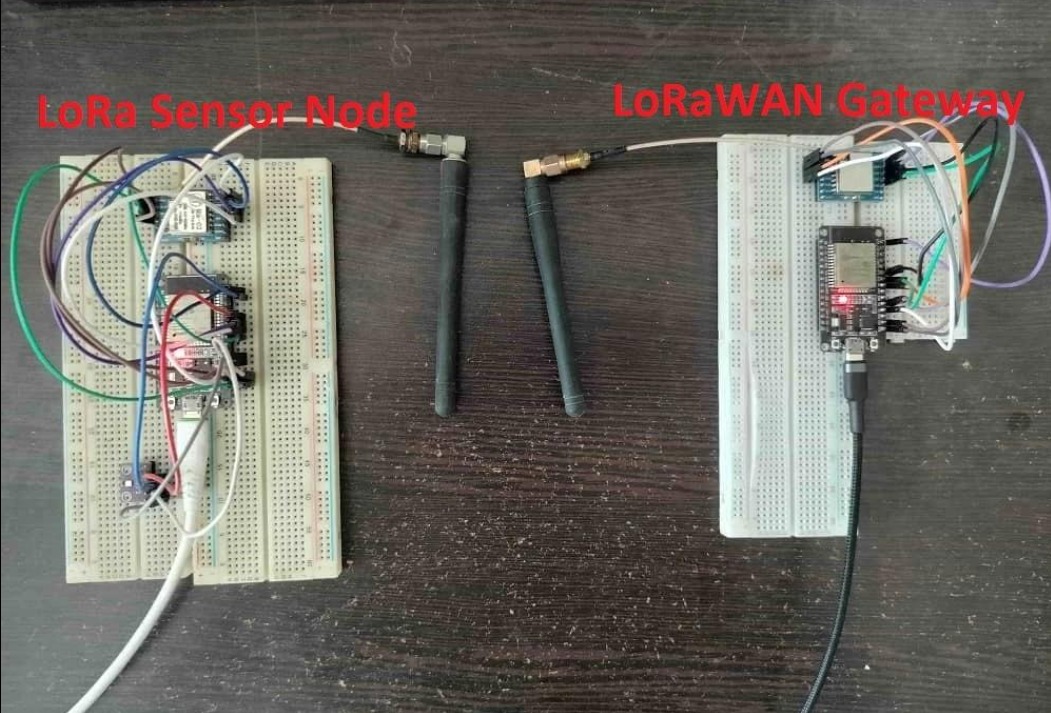
LoRa Sensor Node & Real Gateway Hardware
Hardware demonstration featuring the deployed LoRa sensor node and a real-world LoRaWAN gateway establishing a robust communication link.